Support our educational content for free when you buy through links on our site. Learn more
Robot Design and Building Tips: 10 Smart Ways 🤖

The best Robot Design and Building Tips start with one rule: design for the job, then choose parts that can do it safely and reliably. Define what your robot must accomplish, build a simple prototype, and test each system before adding complexity.
We’ve seen ambitious robots stumble for surprisingly ordinary reasons: a battery mounted too high, a motor driver that couldn’t handle the load, or a wire routed just close enough to snag. Those small details can decide whether a robot glides through a challenge—or spends its big moment tangled in its own wiring.
Key Takeaways
- Start with clear requirements: Define the robot’s task, environment, constraints, and measurable success criteria.
- Design mechanics, electronics, and code as one system: Motor choice, battery capacity, chassis layout, sensors, and software all affect one another.
- Prototype the riskiest feature first: Test uncertain mechanisms before building the complete robot.
- Prioritize safety and repairability: Secure batteries, protect moving parts, add an accessible cutoff, and leave room to inspect and fix components.
- Test methodically: Check one subsystem at a time, record results, and change one thing per test.
- For competition builds, check the current rules first: Weight limits, permitted mechanisms, and safety requirements vary by event.
Table of Contents
- ⚡️ Quick Tips and Facts
- 🤖 Robot Design and Building: The Big Picture
- What Counts as a Robot?
- How Robot Design Connects Mechanics, Electronics, and Code
- 📚 A Short History of Robot Design and Construction
- 🎯 Define Your Robot’s Purpose and Requirements
- Choose a Task, User, and Environment
- Set Goals, Constraints, and Success Criteria
- Plan for Safety, Reliability, and Responsible Design
- 🧠 The Core Elements of a Robot
- Structure, Frame, and Chassis
- Motors, Servos, and Actuators
- Sensors and Feedback
- Controllers, Wiring, and Power
- Software, Algorithms, and Autonomy
- 🛠️ How to Start Building a Robot
- Beginer-Friendly First Robot Projects
- Build a Prototype Before the Final Robot
- Create a Robot Design Brief and Build Plan
- ✏️ Robot Design Process: From Sketch to Working Machine
- Research, Brainstorm, and Sketch Ideas
- Compare Concepts and Choose a Design
- Measure, Model, and Check Clearances
- Document Parts, Wiring, and Revisions
- 💻 Robot Design Software and CAD Tools
- 2D Sketching and Mechanical CAD
- Electronic Circuit and PCB Design
- Robot Simulation and Digital Prototyping
- AI-Assisted CAD: Where It Helps and Where It Doesn’t
- ⚙️ Robot Mechanisms and Motion Design
- Gears, Belts, Chains, and Linkages
- Wheels, Tracks, Legs, and Steering
- Grippers, Arms, and End Effectors
- Balance, Stability, and Center of Gravity
- 🔌 Electronics, Motors, Sensors, and Power Systems
- Choosing a Microcontroller or Single-Board Computer
- Selecting Motors and Matching Drivers
- Choosing Sensors for Your Robot
- Battery Selection, Runtime, and Power Budgeting
- Wiring, Connectors, Fuses, and Electrical Safety
- 💻 Robot Programming and Control
- Write Clear, Testable Robot Code
- Open-Loop and Closed-Loop Control
- Remote Control, Automation, and Autonomous Navigation
- Debuging Sensors, Motors, and Software
- 🏗️ Robot Materials, Fabrication, and Assembly
- Choosing Metal, Plastic, Wood, or 3D-Printed Parts
- 3D Printing Robot Parts That Fit and Last
- Laser Cutting, CNC, and Hand Tools
- Fasteners, Bearings, and Assembly Techniques
- Enclosures, Cable Management, and Weather Protection
- 🧰 Robot Hardware, Parts, Tools, and Kits
- Essential Tools for Robot Building
- How to Choose a Robotics Kit
- When to Use Off-the-Shelf Parts or Custom Components
- 💡 Robot Design Ideas by Type and Purpose
- 1. Simple Line-Following and Obstacle-Avoiding Robots
- 2. Wheled and Tracked Mobile Robots
- 3. Robotic Arms and Pick-and-Place Robots
- 4. Walking Robots and Leged Machines
- 5. Flying Robots and Small Drones
- 6. Combat Robots and Competition Builds
- 7. Toy, Art, and Interactive Robots
- 8. Assistive, Service, and Purpose-Built Robots
- 9. Educational and Builder Robots
- 10. Complex Robots: Humanoids, Rovers, and Multi-Robot Systems
- 🧪 Testing, Troubleshooting, and Improving Your Robot
- Test One Subsystem at a Time
- Common Robot Building Problems and Fixes
- Measure Performance and Refine the Design
- Prepare for Competitions and Demonstrations
- 🔒 Robot Safety, Maintenance, and Long-Term Reliability
- ❓ Frequently Asked Questions About Robot Design and Building
- 🏁 Conclusion
- 🔗 Recommended Links
- 📖 Reference Links
Table of Contents
- ⚡️ Quick Tips and Facts
- 🤖 Robot Design and Building: The Big Picture
- What Counts as a Robot?
- How Robot Design Connects Mechanics, Electronics, and Code
- 📚 A Short History of Robot Design and Construction
- 🎯 Define Your Robot’s Purpose and Requirements
- Choose a Task, User, and Environment
- Set Goals, Constraints, and Success Criteria
- Plan for Safety, Reliability, and Responsible Design
- 🧠 The Core Elements of a Robot
- Structure, Frame, and Chassis
- Motors, Servos, and Actuators
- Sensors and Feedback
- Controllers, Wiring, and Power
- Software, Algorithms, and Autonomy
- 🛠️ How to Start Building a Robot
- Beginer-Friendly First Robot Projects
- Build a Prototype Before the Final Robot
- Create a Robot Design Brief and Build Plan
- ✏️ Robot Design Process: From Sketch to Working Machine
- Research, Brainstorm, and Sketch Ideas
- Compare Concepts and Choose a Design
- Measure, Model, and Check Clearances
- Document Parts, Wiring, and Revisions
- 💻 Robot Design Software and CAD Tools
- 2D Sketching and Mechanical CAD
- Electronic Circuit and PCB Design
- Robot Simulation and Digital Prototyping
- AI-Assisted CAD: Where It Helps and Where It Doesn’t
- ⚙️ Robot Mechanisms and Motion Design
- Gears, Belts, Chains, and Linkages
- Wheels, Tracks, Legs, and Steering
- Grippers, Arms, and End Effectors
- Balance, Stability, and Center of Gravity
- 🔌 Electronics, Motors, Sensors, and Power Systems
- Choosing a Microcontroller or Single-Board Computer
- Selecting Motors and Matching Drivers
- Choosing Sensors for Your Robot
- Battery Selection, Runtime, and Power Budgeting
- Wiring, Connectors, Fuses, and Electrical Safety
- 💻 Robot Programming and Control
- Write Clear, Testable Robot Code
- Open-Loop and Closed-Loop Control
- Remote Control, Automation, and Autonomous Navigation
- Debuging Sensors, Motors, and Software
- 🏗️ Robot Materials, Fabrication, and Assembly
- Choosing Metal, Plastic, Wood, or 3D-Printed Parts
- 3D Printing Robot Parts That Fit and Last
- Laser Cutting, CNC, and Hand Tools
- Fasteners, Bearings, and Assembly Techniques
- Enclosures, Cable Management, and Weather Protection
- 🧰 Robot Hardware, Parts, Tools, and Kits
- Essential Tools for Robot Building
- How to Choose a Robotics Kit
- When to Use Off-the-Shelf Parts or Custom Components
- 💡 Robot Design Ideas by Type and Purpose
- 1. Simple Line-Following and Obstacle-Avoiding Robots
- 2. Wheled and Tracked Mobile Robots
- 3. Robotic Arms and Pick-and-Place Robots
- 4. Walking Robots and Leged Machines
- 5. Flying Robots and Small Drones
- 6. Combat Robots and Competition Builds
- 7. Toy, Art, and Interactive Robots
- 8. Assistive, Service, and Purpose-Built Robots
- 9. Educational and Builder Robots
- 10. Complex Robots: Humanoids, Rovers, and Multi-Robot Systems
- 🧪 Testing, Troubleshooting, and Improving Your Robot
- Test One Subsystem at a Time
- Common Robot Building Problems and Fixes
- Measure Performance and Refine the Design
- Prepare for Competitions and Demonstrations
- 🔒 Robot Safety, Maintenance, and Long-Term Reliability
- ❓ Frequently Asked Questions About Robot Design and Building
⚡️ Quick Tips and Facts
Robot building gets much easier when you design for the job instead of shopping for exciting parts first. A fast motor is not automatically useful, a sensor cannot rescue a poorly placed sensor, and a beautiful chassis that blocks the battery hatch is a very stylish headache.
If your goal is a battle-ready machine, start with our 12-step guide to building a robot for Robot Wrestling. For other projects, the same core process applies: define the task, sketch the design, prototype, build, test, and improve.
| Design decision | Practical starting point | Why it matters |
|---|---|---|
| Purpose | Write one sentence describing the task | Every design choice follows from what the robot must do |
| Mobility | Choose wheels, tracks, legs, or flight for the terrain | The wrong drive system spends power fighting the environment |
| Power | Estimate motor and electronics loads early | A weak supply causes resets, sluggish motors, and overheated wiring |
| Structure | Place heavy components low and secure them firmly | Low, well-secured mass usually improves stability |
| Sensors | Pick sensors for specific decisions the robot must make | Sensors are useful only when their readings can change behavior |
| Testing | Test each subsystem before full assembly | Small faults are easier to find before they become a wire spaghetti mystery |
| Safety | Add an accessible power cutoff and protect moving parts | Safer robots are easier to test, transport, and repair |
Our quick rules of thumb:
- ✅ Prototype the riskiest mechanism first. If the robot’s success depends on a gripper, lifting arm, or unusual wheel setup, test that before building the whole body.
- ✅ Leave room for repairs. A design that takes ten minutes to open is often better than one that looks sleek but requires a full teardown to replace a wire.
- ✅ Separate motor power from logic power where appropriate, and follow the controller and motor-driver documentation for grounding and voltage limits.
- ❌ Do not power motors directly from a microcontroller pin. Use a suitable motor driver; GPIO pins are for control signals, not motor current.
- ❌ Do not assume a battery’s voltage rating tells you its full capability. Current delivery, protection circuitry, connector ratings, and runtime matter too.
- ✅ Keep a test log. Write down what changed, what improved, and what got worse. Your future self is an excellent engineer but a famously unreliable filing cabinet.
For a structured introduction to competitive robot design, the FLL Masterclass video on robot design offers a championship-coach perspective. We’ll return to the broader question behind every successful build: what should your robot be designed to do?
🤖 Robot Design and Building: The Big Picture
Robot design is the practice of turning a task into a machine that can sense, decide, and act. Building adds the practical work: choosing parts, making the structure, wiring it safely, programming behavior, and learning from tests.
The trick is that those activities are connected. A chassis determines where motors can fit. Motor choice affects battery size. Battery size changes weight and balance. Weight changes how much torque the motors need. And the software can only control the hardware you actually built. Robotics is less like assembling separate puzzle pieces and more like cooking a meal where every ingredient affects the others.
A useful workflow is:
- Define the task and environment.
- List constraints such as size, weight, runtime, cost, and safety.
- Sketch possible designs before committing to parts.
- Prototype the uncertain features.
- Build a modular robot that is easy to inspect and revise.
- Test against measurable goals.
- Improve one important weakness at a time.
This process appears across very different robotics fields. The NASA Systems Engineering Handbook describes systems engineering as an iterative way to understand requirements, manage interfaces, and verify that a complete system performs as intended. That thinking works just as well for a classroom rover as for a battle robot.
What Counts as a Robot?
There is no single everyday definition that covers every machine people call a robot. Most practical robots combine some ability to sense information, process it, and affect the physical world. A remotely controlled rover has limited autonomy but is still a robot; an autonomous robot makes some decisions without continuous human commands.
A basic robot might contain:
- A frame or chassis
- One or more actuators, such as motors or servos
- A controller
- A power source
- Sensors or a human-control interface
- Software or control logic
Not every robot needs every part. A simple vibrating brush bot may have no microcontroller. A teleoperated machine may rely on a human operator rather than onboard decision-making. The design should fit the task, not an imaginary checklist of “proper robot” features.
How Robot Design Connects Mechanics, Electronics, and Code
Four disciplines meet in nearly every build:
| Discipline | Main question | Example |
|---|---|---|
| Mechanisms | How will the robot move or manipulate objects? | Gear reduction lets a small motor turn a wheel with greater torque |
| Electronics | How will power and signals reach each component? | A motor driver switches current to a DC motor |
| Programming | How should the robot interpret inputs and choose actions? | A line-following program adjusts motor speeds from reflectance readings |
| Fabrication | How will the parts be made, assembled, and protected? | A laser-cut plate holds the controller and motor mounts |
As Ponoko’s robot-building guide emphasizes, the disciplines belong together: mechanism choices shape electronics and code, while the body must accommodate the components. We agree. At Robot Wrestling™, we have seen a drive system look brilliant on a workbench and then fail because its battery sat too high or its wiring snaged on the weapon mount. The fix was not “better code”; it was better integration.
📚 A Short History of Robot Design and Construction

Robot design has moved from mechanical automata to programmable machines and networked, sensor-rich systems. The word “robot” became widely known through Karel Čapek’s 1920 play R.U.R., while industrial robotics grew rapidly with programmable factory machines such as Unimate, installed at a General Motors plant in 1961. The Smithsonian’s account of Unimate gives a useful look at one landmark industrial automation.
| Era | Design shift | What changed |
|---|---|---|
| Ancient to early modern | Automata and mechanical devices | Cams, gears, springs, and linkages produced repeatable motion |
| 20th century | Programmable industrial machines | Electronics and control systems enabled robots to perform repeated factory tasks |
| Late 20th century | Educational and hobby robotics | Affordable microcontrollers and kits brought robot building to schools and workshops |
| 21st century | Networked, mobile, and collaborative robots | Better sensors, computing, batteries, and software expanded what small robots can do |
Modern robot design is not just about more powerful hardware. Accessible boards such as the Arduino and Raspberry Pi let hobbyists experiment with sensing, control, and connectivity. Meanwhile, FIRST programs and other educational leagues make engineering practice part of a team challenge. You can explore our coverage of robot competitions in Robot Wrestling™ Competitions and the wider history of robot wrestling.
One lesson has survived every technological leap: a reliable robot is usually the product of careful iteration, not one dazzling late-night idea.
🎯 Define Your Robot’s Purpose and Requirements
Before choosing a motor, write down what the machine must accomplish. “Build a cool robot” is an excellent invitation to experiment but a poor engineering requirement. “Drive across a marked arena, turn within a 60-centimeter space, and push a target without losing traction” gives you something you can design and test.
For battle machines, clarify whether the objective is pushing, controlling, surviving, or scoring under a particular rule set. Robot wrestling formats vary, so verify the specific event’s rules before ordering parts or machining a weapon.
Choose a Task, User, and Environment
Ask these questions:
- What is the robot supposed to do?
- Who operates or benefits from it?
- Where will it work? Smooth floor, carpet, outdoor ground, arena, water, or a controlled classroom?
- What must it touch, carry, detect, or avoid?
- Will it be autonomous, remote-controlled, or a mix of both?
- How will it be transported, charged, inspected, and repaired?
The environment can change the design dramatically. A small indoor rover may need quiet motors and soft wheels; a dusty outdoor robot needs protection for bearings and electronics. A competition robot must fit the league’s inspection and safety requirements, not just the builder’s imagination.
Set Goals, Constraints, and Success Criteria
Turn vague goals into measurable tests. For example:
| Requirement | Example measure |
|---|---|
| Mobility | Cross a specified floor surface without getting stuck |
| Turning | Complete a turn inside the required footprint |
| Payload | Carry the intended load without excessive motor heating |
| Runtime | Operate for the full planned session with a reserve |
| Sensing | Detect a target at a repeatable distance or under stated lighting |
| Reliability | Complete repeated trial runs without a critical failure |
| Safety | Power can be disabled quickly and safely |
The right numbers depend on your project. Do not borrow a specification from another robot unless its use case, mass, surface, and motor setup are comparable.
Plan for Safety, Reliability, and Responsible Design
Build safety into the design rather than adding it after a test goes sideways. Use an accessible master switch, secure battery mounting, strain relief for wiring, and guards around pinch points. For a weaponized competition machine, use the event’s approved safety system, weapon lock, and inspection process. The NHRL safety rules are an example of the kind of detailed event-specific guidance competitors should read; they are not a substitute for the rules of your own league.
Robot Wrestling™ fans love a dramatic match. Engineers love when everyone leaves with all their fingers. Both groups are right.
🧠 The Core Elements of a Robot
A robot’s structure, actuators, sensors, controller, power source, and software form one system. Treating them as a matched set prevents familiar headaches: motors that stall, sensors that lie, connectors that melt, and batteries that are impossible to reach.
Structure, Frame, and Chassis
The chassis carries components and transfers forces through the robot. A good one is not merely strong; it is strong where loads occur, light where strength is unnecessary, and accessible enough to repair.
Think about:
- Motor and wheel mounting
- Battery restraint
- Controller access
- Cable routing
- Ground clearance
- Protective panels
- Serviceability
- The direction of expected impacts or loads
For a mobile robot, place heavy components low and avoid concentrating all the weight one small area. For a combat robot, the frame and armor must match the event’s weight class and rules. A thin plate can be plenty for a classroom rover but inappropriate for a high-energy arena machine.
Motors, Servos, and Actuators
Actuators produce motion. Common options include:
- Brushed DC motors: Simple speed control and widely used in small drive systems.
- Gearmotors: DC motors paired with gears to trade speed for torque.
- Servos: Convenient for controlled angular positioning; check whether the servo is positional or continuous-rotation.
- Brushless motors: Efficient and powerful, but require compatible electronic speed controllers and appropriate setup.
- Steppers: Useful for controlled step-based motion, though they can lose position under excessive load.
- Linear actuators: Move components along a straight path.
Never choose a motor based only on its no-load speed. Check its rated voltage, continuous current, stall current, torque, thermal limits, and the driver’s ratings. A stalled motor can draw far more current than it does while spinning freely.
Sensors and Feedback
Sensors give the robot information. Common examples include:
| Sensor | Useful for | Watch out for |
|---|---|---|
| Ultrasonic distance sensor | Approximate obstacle distance | Soft surfaces and angled objects may give unreliable echoes |
| Infrared reflectance sensor | Line following and surface detection | Ambient light and surface color affect readings |
| Encoders | Wheel rotation and distance estimation | Wheel slip means rotation is not exactly ground travel |
| IMU (accelerometer and gyroscope) | Motion, tilt, and rotation estimates | Sensor bias and vibration need consideration |
| Limit switch | Detecting a physical end position | Mechanical alignment and switch travel matter |
| Camera | Vision and object recognition | Lighting, compute load, and latency can complicate control |
A sensor is not automatically useful because it is sophisticated. A simple switch placed well can outperform a camera placed badly. Decide what information the robot needs, then choose a sensor whose performance matches that decision.
Controllers, Wiring, and Power
The controller runs the program, but power electronics make its commands physically possible. A microcontroller usually cannot supply the current a motor needs, so motor drivers, regulators, and suitable wiring are essential.
The Arduino documentation and Raspberry Pico documentation explain the capabilities and limits of their platforms. Always check the exact board’s pin voltage, current limits, operating voltage, and peripheral support.
A dependable layout usually includes:
- A battery matched to the system voltage and current demand
- A regulator for electronics that need a different voltage
- Motor drivers rated for expected continuous and peak current
- A common signal reference where the circuit design requires it
- A fuse or other protection appropriate to the power system
- Connectors that cannot be easily reversed or pulled loose
Software, Algorithms, and Autonomy
Software connects sensor readings to actions. It might be as simple as “if the bumper switch is pressed, reverse and turn,” or as complex as mapping a room and planning a route.
Keep the first program understandable:
- Read an input.
- Check whether the input is plausible.
- Decide on an action.
- Send the action to the actuator.
- Repeat at a predictable rate.
- Log important faults or measurements.
The ROS 2 documentation is useful when a project grows into a multi-node robotics system, but a beginner’s two-motor rover probably does not need a software architecture large enough to require its own office manager.
🛠️ How to Start Building a Robot
Start with a robot that teaches you the foundations without making every subsystem a mystery at once. A simple two-wheel rover is a strong first project because it introduces a chassis, motor driver, battery, controller, and basic control logic.
If you’re interested in competitive builds, the FLL Masterclass robot-design video gives an accessible look at competition strategy and design decisions. The video is aimed at FIRST LEGO League, so treat its advice as helpful design guidance rather than a rulebook for other leagues.
Beginner-Friendly First Robot Projects
| Project | Skills you practice | Why it makes a good first build |
|---|---|---|
| Brush bot | Circuits and vibration | Minimal parts; fast feedback |
| Line follower | Sensor calibration and motor control | Demonstrates closed-loop behavior |
| Obstacle-avoiding rover | Distance sensing and conditional logic | Makes robot decisions visible |
| Micro:bit buggy | Blocks, radio control, and sensors | Beginner-friendly hardware and learning resources |
| Small robot arm | Servos, linkages, and coordinate thinking | Teaches mechanism design and careful movement |
The BBC micro:bit and its MakeCode editor are designed for accessible physical computing. For LEGO-based learning, FIRST LEGO League provides age-based programs and team challenges. A kit can reduce sourcing work, but it should still teach you why components work, not only which connector goes where.
Build a Prototype Before the Final Robot
A prototype answers a question. It may be temporary, ugly, taped together, and exactly right.
Try this approach:
- Identify the biggest design risk. Is it traction, balance, sensing, gripping, or runtime?
- Build a minimal test rig for that feature only.
- Measure what happens. Record speed, repeatability, current, or success rate.
- Change one variable at a time.
- Keep the parts that work and redesign the rest.
If the robot must climb a ramp, test the wheel size, traction material, and motor gearing on a small platform before designing a full enclosure. If a grapling arm must grab a target, test the gripper geometry before adding decorative armor. The quickest path to a dependable robot is often a pile of small experiments.
Create a Robot Design Brief and Build Plan
Write a short design brief with:
- Project purpose and operating environment
- Required behavior and success tests
- Size, mass, and runtime constraints
- Safety requirements
- Main subsystems and their interfaces
- Parts you already own and parts you need
- Risks, unknowns, and prototype experiments
- A simple build and test schedule
This is especially useful for teams. Agreeing that “the robot should be fast” means little until everyone agrees whether speed, turning, pushing force, or control matters most.
✏️ Robot Design Process: From Sketch to Working Machine
A disciplined process helps you make good decisions before they become expensive to change. You do not need perfect engineering drawings for a first build, but you do need enough information to know where parts go and how they connect.
Research, Brainstorm, and Sketch Ideas
Start with several concepts rather than falling in love with the first one. Sketch side, top, and front views. Mark the battery, controller, motors, wheels, sensors, moving parts, and service access.
For each concept, ask:
- Can it perform the task?
- Can it be built with available tools?
- Can you access the parts that will need maintenance?
- Does it meet safety and competition constraints?
- What assumption should you test first?
Use the NASA Systems Engineering Handbook as a reference for requirements and verification concepts. For educational teams, the FIRST LEGO League resources library includes season resources and team materials.
Compare Concepts and Choose a Design
Rate design options against criteria that matter to your project. A simple weighted score can expose trade-offs:
| Criterion | Weight | Concept A score | Concept B score |
|---|---|---|---|
| Task performance | 5 | 4 | 3 |
| Ease of building | 3 | 3 | 5 |
| Repair access | 4 | 2 | 4 |
| Safety | 5 | 4 | 4 |
| Room for upgrades | 2 | 5 | 3 |
Multiply each score by its weight, then compare the totals. The numbers are not magic; the discussion behind them is the useful part. If a team strongly disagrees, that may reveal an untested assumption.
Measure, Model, and Check Clearances
Measure actual parts whenever possible. “Looks about right” is not a reliable method for a motor mount, battery bay, wheel opening, or gear mesh.
Check:
- Hole spacing and shaft diameter
- Wheel clearance through the full steering range
- Battery removal path
- Cable bend radius and connector access
- Moving-part clearance
- Center of gravity and ground clearance
- Fastener access for assembly and maintenance
For a competition robot, also confirm the official measurement method and any inspection allowances. Event rules can define dimensions differently from a casual ruler check.
Document Parts, Wiring, and Revisions
Keep a bill of materials, wiring diagram, CAD files, and revision notes. Label connectors and record what changed after each test.
A useful revision note looks like this:
Revision 3: moved the battery 20 mm lower; reduced top-heavy woble on turns; still needs a more secure strap.
That sentence saves a surprising amount of “Why did we do this again?” later.
💻 Robot Design Software and CAD Tools
Software can help you visualize the robot, check fit, simulate motion, and document circuits. Pick tools that suit the project and your team’s experience rather than choosing the most complicated platform just because it has impressive screenshots.
2D Sketching and Mechanical CAD
For flat chassis plates and laser-cut parts, 2D vector software can be enough. For assemblies, moving joints, and detailed part designs, use 3D CAD.
Options include:
- Autodesk Fusion for mechanical CAD, assemblies, and manufacturing workflows
- Onshape for browser-based collaborative CAD
- FreeCAD for open-source parametric 3D design
- Inkscape for vector drawings and 2D fabrication layouts
Set a consistent unit system and model actual component dimensions. A beautifully detailed model based on imaginary dimensions is basically an engineering-themed daydream.
Electronic Circuit and PCB Design
Circuit tools help you draw connections and design custom boards. KiCad is a widely used open-source option for schematic capture and PCB layout. Before ordering a board, verify footprints, clearances, connector orientation, and current paths. Prototype the circuit on a breadboard or modular board first if that is suitable for the components.
Robot Simulation and Digital Prototyping
Simulation can help explore motion, control logic, and sensor behavior, but it cannot perfectly reproduce every real-world effect. Friction, flexible parts, wheel slip, battery sag, and imperfect assembly all matter.
Useful tools and platforms include:
- Webots for robot simulation
- Gazebo for robotics simulation and testing
- MATLAB and Simulink for modeling and control workflows
Treat simulation as a way to find problems earlier, not as proof that the physical robot will behave identically.
AI-Assisted CAD: Where It Helps and Where It Doesn’t
AI tools can help brainstorm mechanisms, explain a CAD feature, draft simple code, or suggest a design checklist. They can also invent dimensions, overlook electrical ratings, or generate a part that cannot be manufactured as drawn.
Use AI-generated designs as drafts to inspect, not as engineering approval. Verify geometry in CAD, check electrical ratings against manufacturer documentation, and test physical prototypes. If a generated design includes a high-speed mechanism or battery system, have a qualified adult or engineer review it before testing.
⚙️ Robot Mechanisms and Motion Design
Mechanisms translate motor motion into useful movement. The right choice depends on the force, speed, precision, terrain, and maintenance demands of the task.
Gears, Belts, Chains, and Linkages
| Mechanism | Benefits | Drawbacks | Good fit |
|---|---|---|---|
| Gears | Compact, direct power transfer | Alignment and lubrication can matter | Gearboxes and compact drives |
| Timing belts | Quiet and forgiving; no slip when matched correctly | Belt tension and tooth profile need care | Motion transmission and positioning |
| Chains | Durable and useful for larger loads | Need tensioning and guarding | Heavy-duty drive systems |
| Linkages | Convert motion into a chosen path | Geometry can be unintuitive | Grippers, legs, and lifting mechanisms |
| Lead screws | Controlled linear movement | Slower and can bind if misaligned | Lifts and linear stages |
Reducing speed with gearing can increase output torque, but real systems lose power through friction and other inefficiencies. The useful design question is not “How much torque does the motor advertise?” but “Can the whole drive train deliver the motion the robot needs without overheating or breaking?”
Wheels, Tracks, Legs, and Steering
- Wheels: Efficient on smooth surfaces and usually the easiest mobile design to build.
- Tracks: Spread load and can help on loose terrain, but often add friction and complexity.
- Legs: Handle obstacles and unusual terrain, but need careful control and mechanical coordination.
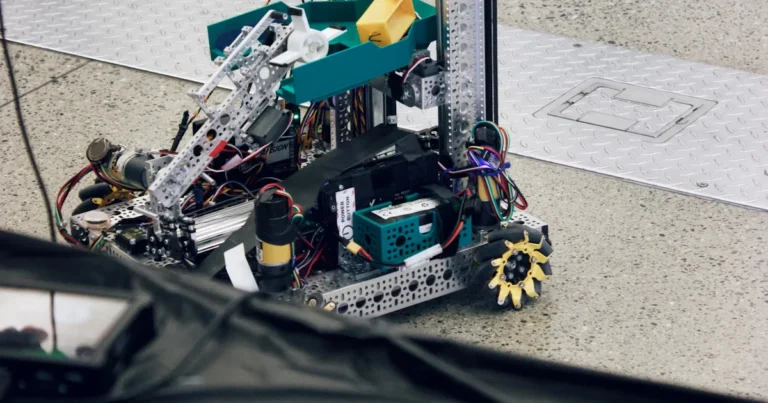
- Mecanum wheels: Allow sideways movement on suitable surfaces, but require correct wheel orientation and can be less efficient on rough ground.
- Differential drive: Two independently driven sides provide simple, reliable turning.
A wheled rover is a strong first build because it makes motion and control easier to understand. The ROS 2 mobile robot tutorials and platform-specific guides can help when a project grows beyond basic motor commands.
Grippers, Arms, and End Effectors
The end effector is the part that interacts with an object: a gripper, scoop, hook, pusher, tool, or sensor head.
When designing one:
- Identify object size, shape, weight, and material.
- Choose a contact method: friction, enclosure, hook, magnet, suction, or support underneath.
- Estimate the force needed and the geometry required.
- Place the actuator to avoid unnecessary leverage penalties.
- Add stops to prevent overtravel.
- Test with representative objects, not just the easiest one.
A powerful servo cannot compensate for a gripper that misses the object by two centimeters. Geometry first, actuator second.
Balance, Stability, and Center of Gravity
For many mobile robots, lowering the center of gravity reduces the tendency to tip. Keep heavy components secure and avoid tall, narrow layouts unless the robot’s control system is designed to stabilize them.
For a battle robot, stability also depends on wheel contact, weapon forces, armor geometry, and how the machine behaves after a hit. No single feature makes a robot “unflippable.” Design for recovery, protect vulnerable systems, and test the full configuration under controlled conditions.
🔌 Electronics, Motors, Sensors, and Power Systems
A dependable robot depends on matching electrical components—not just plugging parts together until a light turns on. Check each part’s operating voltage, current, signal type, and thermal limits.
Choosing a Microcontroller or Single-Board Computer
| Platform | Strengths | Considerations |
|---|---|---|
| Arduino Uno and compatible boards | Simple microcontroller projects and extensive learning material | Limited computing compared with a full computer; board versions differ |
| BBC micro:bit | Beginner-friendly learning, built-in features, block coding | Not intended to power motors directly |
| Raspberry Pico / Pico W | Microcontroller control with MicroPython or C/C++; Pico W adds wireless connectivity | Requires appropriate drivers and power design |
| Raspberry Pi computer | Linux, networking, camera and higher-level software options | More power draw and startup complexity than a basic microcontroller |
Choose the platform based on inputs, outputs, processing needs, connectivity, and the software you can maintain. The board is the robot’s coordinator, not its entire brain-in-a-box solution: motor drivers, power supplies, sensors, and code still need to be designed around it.
Selecting Motors and Matching Drivers
To choose a motor:
- Estimate the robot’s mass and required movement.
- Decide on wheel diameter, desired speed, and terrain.
- Estimate the torque needed at the wheel.
- Select a motor and gear ratio with appropriate headroom.
- Check stall current and continuous operating limits.
- Select a driver rated for the motor’s voltage and expected current.
- Test motor temperature and performance under realistic load.
Use manufacturer datasheets wherever possible. Do not assume that a motor driver’s headline current rating applies continuously in your robot’s enclosure; cooling, PCB design, and operating conditions affect real performance.
Choosing Sensors for Your Robot
Choose sensors based on the decision they support. For instance:
- A line sensor can support line-following correction.
- Wheel encoders can estimate distance traveled.
- A limit switch can stop a mechanism at a known endpoint.
- An IMU can estimate tilt and rotation.
- A distance sensor can support obstacle avoidance.
Before relying on a sensor, test its readings in the actual environment. Dark surfaces, bright sunlight, vibration, and moving targets can change performance. Filter noisy readings when appropriate, and make sure a sensor failure does not cause an unsafe action.
Battery Selection, Runtime, and Power Budgeting
Plan power early. A useful budget lists the voltage and expected current of each subsystem:
| Subsystem | Supply requirement | Current estimate | Notes |
|---|---|---|---|
| Controller | From board documentation | Measure or use rated load | Include attached modules |
| Drive motors | Motor rating and load | Check stall and operating current | Large variation with terrain |
| Sensors | Datasheet values | Usually lower, but add them up | Include heaters or LEDs |
| Wireless or compute modules | Documentation | Depends on activity | Peak loads can matter |
| Actuator or weapon system | Event-approved design | Verify peak demand carefully | Requires especially careful safety review |
For an approximate runtime estimate, divide usable battery capacity by average system current, then account for conversion losses, battery condition, peak loads, and safe discharge limits. It is a planning estimate, not a guaranteed clock.
Battery chemistry matters. Follow the manufacturer’s charging, storage, protection, and disposal instructions. For lithium-based packs, use compatible chargers and inspect packs for damage. The U.S. Consumer Product Safety Commission’s battery safety guidance offers general consumer-safety information.
Wiring, Connectors, Fuses, and Electrical Safety
- Choose wire gauge for current and run length.
- Secure cables away from gears, wheels, and hot components.
- Use connectors rated for the expected current.
- Add strain relief to wires that may flex.
- Protect against accidental shorts.
- Label connectors and observe polarity.
- Follow board and driver documentation for grounding and signal connections.
A battery that can deliver high current can turn a minor wiring mistake into a serious hazard. Work with power disconnected whenever possible, and use suitable protective measures for the battery chemistry and application.
💻 Robot Programming and Control
Good robot software is predictable, testable, and designed to handle bad inputs. Start with simple behavior, then add complexity when tests show it is needed.
Write Clear, Testable Robot Code
Break the program into functions such as:
read_sensors()estimate_state()choose_action()set_motor_output()check_safety()
Keep constants—such as speed limits and sensor thresholds—in one place. Add comments that explain why a decision exists, not merely what the line of code says.
For beginner projects, Arduino’s programming documentation and MicroPython’s documentation are useful starting points. Test code with motors disconnected or wheels lifted where practical before allowing the robot to drive freely.
Open-Loop and Closed-Loop Control
Open-loop control sends a command without measuring whether the intended result happened. Closed-loop control uses feedback to adjust behavior.
Example:
- Open loop: run a motor for two seconds and assume the robot traveled the desired distance.
- Closed loop: use encoder readings to measure wheel rotation and adjust motor output.
Closed-loop control can improve repeatability, but it depends on good sensors, sensible calibration, and a control algorithm suited to the system. Feedback cannot fix an incorrectly wired encoder or a wheel that spins freely on the floor.
Remote Control, Automation, and Autonomous Navigation
A robot can be:
- Teleoperated: A person sends movement commands.
- Automated: It follows a prearranged sequence.
- Autonomous: It senses and selects actions without continuous operator input.
- Hybrid: Human commands and onboard behavior work together.
For radio-controlled robots, test signal loss behavior. Decide in advance whether the robot should stop, disable a mechanism, or take another safe action if communication drops. For autonomous navigation, test under the same lighting, surface, and obstacle conditions expected in real use.
Debuging Sensors, Motors, and Software
Debug methodically:
- Reproduce the fault.
- Decide which subsystem could cause it.
- Test that subsystem by itself.
- Record measurements or logs.
- Change one thing.
- Repeat the same test.
A robot that vers left may have uneven motor output, wheel alignment issues, different tire friction, an uncalibrated sensor, or a code bug. Swap motor connections or components one at a time to narrow the cause. Randomly changing five settings at once is not debugging; it is asking chaos to do consulting.
🏗️ Robot Materials, Fabrication, and Assembly
A material is useful when its strength, weight, cost, machinability, and environment fit the design. The best material for a decorative shell may be a poor choice for a load-bearing bracket.
Choosing Metal, Plastic, Wood, or 3D-Printed Parts
| Material | Benefits | Limitations | Common uses |
|---|---|---|---|
| Aluminum | Good strength-to-weight ratio; machinable | Can bend or deform under concentrated loads | Plates, brackets, frames |
| Steel | Strong and durable | Heavy; more challenging to cut and form | High-load components and protective structures |
| Acrylic | Easy to laser cut; clean appearance | Can crack under impact and stress concentration | Enclosures and visual prototypes |
| Plywood | Affordable, easy to work, useful for prototypes | Moisture and layer direction affect strength | Chassis plates and learning projects |
| PETG or nylon prints | Custom shapes and rapid iteration | Print direction, heat, and material affect strength | Brackets, mounts, covers |
| Polycarbonate | Tough and impact resistant | Cutting and forming need suitable methods | Guards and protective panels |
Material properties vary by grade, manufacturing process, and geometry. For safety-critical or high-load parts, rely on manufacturer datasheets and appropriate testing.
3D Printing Robot Parts That Fit and Last
For a printed component:
- Orient the part so expected loads do not peel layers apart.
- Add filets around high-stress corners.
- Use sufficient wall thickness and appropriate infill for the load.
- Design holes and press fits for the printer’s actual tolerances.
- Avoid putting a tiny screw directly into a thin printed wall.
- Test printed parts under controlled conditions before relying on them.
Prusa’s material guides explain common filament properties and printing considerations. A printed part may look solid while having weak layer adhesion. Orientation and load direction matter as much as the plastic name on the spool.
Laser Cutting, CNC, and Hand Tools
- Laser cutting is excellent for repeatable 2D profiles, flat plates, and enclosures.
- CNC milling can create more complex shapes and accurate pockets, but requires planning and safe operation.
- Hand tools are accessible and versatile, especially for prototypes and repairs.
- 3D printing is useful for complex geometry and quick custom fixtures.
Follow tool manufacturer instructions, use appropriate ventilation and personal protective equipment, and confirm that a material is safe for the machine. Not every plastic is suitable for laser cutting; verify the material with the machine provider.
Fasteners, Bearings, and Assembly Techniques
Use fasteners that match the load and material. Washers can distribute force; thread-locking products may help where vibration loosens screws, but follow their instructions and material compatibility.
For rotating shafts:
- Support the shaft with correctly sized bearings.
- Align the motor, coupler, and driven component.
- Avoid forcing a bearing into a misaligned mount.
- Check for binding before powering the system.
- Use guards where moving parts could catch fingers or clothing.
Build in modules when possible. A replaceable motor plate or battery tray can turn a frustrating repair into a quick pit-side fix.
Enclosures, Cable Management, and Weather Protection
An enclosure should protect parts without blocking cooling, service access, or sensor visibility. Route wires away from moving components and leave enough slack for vibration without creating loops that can snag.
For outdoor robots, assess water, dust, temperature, and condensation risks. A sealed box can trap heat, and an enclosure’s rating depends on proper assembly and cable glands—not merely the plastic box itself. Choose protection based on the actual environment.
🧰 Robot Hardware, Parts, Tools, and Kits
A useful workshop does not need every machine in a fabrication shop. It does need safe, suitable tools and a plan for obtaining compatible parts.
Essential Tools for Robot Building
A practical starter setup may include:
- Screwdrivers and hex keys
- Wire strippers and flush cutters
- Multimeter
- Soldering iron and safe soldering station
- Helping hands or a stable work holder
- Small pliers and adjustable wrench
- Heat-shrink tubing
- Calipers or a ruler
- Safety glasses
- Appropriate battery charger
A bench power supply can be useful for controlled testing, but it is not a replacement for a proper battery system in a mobile robot. Learn to use a multimeter safely; a quick voltage check can prevent hours of unnecessary code edits.
How to Choose a Robotics Kit
Look for a kit with:
- Clear instructions and wiring diagrams
- Parts that can be reused beyond one build
- A controller suited to your learning goals
- Support for the programming language you want to learn
- Replacement-part availability
- Safe, age-appropriate components
- Room to modify the design
Examples include micro:bit, LEGO Education, and Arduino starter resources. Kits are a launchpad, not a design ceiling. Once you understand the system, modify one feature and observe what changes.
When to Use Off-the-Shelf Parts or Custom Components
Use off-the-shelf parts when they meet the requirement and are easy to replace. Custom parts make sense when they solve a real fit, weight, strength, or function problem.
Good reasons to customize:
- The standard part does not fit the chassis
- You need a specific mounting pattern
- A mechanism requires a particular shape
- You need to reduce unnecessary mass
- The design would be simpler or safer with a tailored component
Avoid custom parts just to make a build look more advanced. In engineering, “we could make it” is not the same as “we should make it.”
💡 Robot Design Ideas by Type and Purpose
These project types make useful starting points, but the best one depends on your skills, workspace, and goals. If you want to compete, check the rules before designing around a feature that may not be permitted.
1. Simple Line-Following and Obstacle-Avoiding Robots
A line follower uses reflectance sensors to detect a path and adjusts its motors to stay on course. An obstacle-avoiding rover uses a distance sensor, bumper, or other input to change direction.
Skills: sensor calibration, motor control, thresholds, feedback.
Build tip: test sensor readings on the actual surface and lighting. A glossy floor can behave differently from matte paper.
2. Wheled and Tracked Mobile Robots
A two-wheel differential-drive rover is one of the most practical first builds. Mecanum-wheel platforms can move sideways on smooth surfaces, while tracked bases can handle some rough terrain at the expense of added friction and complexity.
Skills: chassis layout, traction, turning, power budgeting.
Trade-off: wheels are usually simpler and more efficient on flat ground; tracks and specialized wheel systems solve particular mobility problems, not every mobility problem.
3. Robotic Arms and Pick-and-Place Robots
A small arm teaches joints, leverage, servo control, gripper design, and repeatable positioning. Start with a lightweight payload and a short reach. Longer arms increase torque demands quickly.
Build tip: mark joint limits in software and add mechanical stops where appropriate. Test the arm without a payload before lifting anything valuable.
4. Walking Robots and Leged Machines
Leged robots can handle obstacles that stop wheled platforms, but they need more actuators and careful coordination. A hexapod often has a broader support pattern than a biped, while a two-legged robot needs active balance strategies or a deliberately stable gait.
Projects such as Petoi’s open-source robot platforms can help builders explore gait and servo control. Expect calibration and mechanical adjustment; legs are not just wheels with extra paperwork.
5. Flying Robots and Small Drones
Multirotor aircraft require careful integration of motors, propellers, flight controllers, batteries, and radio links. They also carry significant safety responsibilities. Begin with a suitable educational or ready-to-fly platform, follow local aviation rules, and keep people clear during tests.
The FAA’s recreational drone guidance explains U.S. requirements for recreational flyers. Rules differ by country, so verify your local requirements before flight.
6. Combat Robots and Competition Builds
Combat robots combine drive, armor, control, and strategic design under strict safety and event constraints. A reliable drive system and a robust serviceable chassis often matter more than a dramatic feature that fails after one impact.
Before building:
- Confirm the league’s weight class and permitted mechanisms.
- Read inspection and safety rules.
- Design around the arena and match format.
- Secure batteries and protect wiring.
- Make weapon disarming straightforward.
- Test the robot in a controlled, approved environment.
You can follow our competition coverage, read event announcements, and revisit notable famous matches for examples of how design choices affect performance. We’ll get into more competition-specific design considerations in the FAQ.
7. Toy, Art, and Interactive Robots
Toy and art robots combine movement with personality: expressive lights, sounds, gestures, drawings, or interactive behavior. Keep the mechanism dependable and make the interaction obvious. A robot with a playful face can still use serious engineering underneath.
Project ideas: a drawing bot, a light-seking toy, a moving display, a musical robot, or an interactive desk companion.
8. Assistive, Service, and Purpose-Built Robots
Purpose-built robots solve a defined problem, such as carrying supplies, monitoring plants, or helping with repetitive tasks. Consider user needs, accessibility, privacy, maintenance, and what happens when the robot fails.
For anything intended to support health, mobility, or safety, involve qualified users and professionals early. A prototype should not be treated as a certified assistive device.
9. Educational and Builder Robots
Educational robots help learners practice mechanical design, coding, teamwork, and testing. FIRST LEGO League uses a team-based challenge format, while platforms such as micro:bit and Arduino support open-ended projects.
The official FIRST LEGO League season materials include the 2026–27 BIOGLOW resources for FIRST LEGO League Explore. They list the Engineering Notebook, Explore Set instructions, team meeting materials, and related season resources. These materials support the program’s learning activities; they are not general specifications for every robot competition.
10. Complex Robots: Humanoids, Rovers, and Multi-Robot Systems
Advanced robots combine many subsystems: vision, localization, planning, manipulation, communications, and fault handling. Start by understanding a simpler subsystem before integrating everything.
For example, build and test a reliable rover before adding mapping; get a dependable arm before adding vision-based pick-and-place. Large robot projects become manageable when they are divided into small systems with clear interfaces.
🧪 Testing, Troubleshooting, and Improving Your Robot
Testing should begin early and continue throughout the build. One full-system test at the very end is a dramatic way to discover that the battery connector is backwards.
Test One Subsystem at a Time
A practical test sequence:
- Inspect the mechanical assembly with power off.
- Check wiring continuity and polarity.
- Power the controller without motors.
- Test each sensor and confirm readings.
- Test each motor at low power with wheels lifted if appropriate.
- Test movement on the ground in a clear area.
- Add the payload, mechanism, or full operating behavior.
- Run repeated trials and inspect for heat, looseness, and wear.
Keep test conditions consistent. If you change the battery, surface, and code simultaneously, you will not know which change caused the result.
Common Robot Building Problems and Fixes
| Symptom | Possible causes | First checks |
|---|---|---|
| Controller resets when motors start | Voltage sag, poor wiring, electrical noise, inadequate supply | Check battery condition, wiring, driver setup, and power separation |
| Robot turns unevenly | Motor variation, wheel alignment, traction difference, code mismatch | Swap motors, inspect wheels, calibrate outputs |
| Motor overheats | Excess load, stalled mechanism, wrong gearing, inadequate cooling | Check for binding and compare load with motor ratings |
| Sensor readings jump | Noise, poor mounting, lighting, vibration, incorrect filtering | Test static readings and adjust mounting or signal processing |
| Robot drifts from a line | Sensor position, thresholds, uneven drive, poor tuning | Calibrate on the actual path and inspect the chassis |
| Screws loosen | Vibration, unsuitable fastener, poor joint design | Check fit, add appropriate locking method, inspect material |
| Battery runtime is short | High motor load, old battery, inefficient driver, oversized system | Measure current and compare against expected load |
If a fault appears suddenly, inspect physical connections before rewriting the entire program. Software is an easy suspect because it is visible; loose hardware is often the less glamorous culprit.
Measure Performance and Refine the Design
Choose a few measurements related to the task:
- Distance traveled or speed
- Turning accuracy
- Repeatability
- Payload capacity
- Battery runtime
- Motor temperature
- Completion rate across repeated trials
- Recovery time after a fault
Make a change only when the test results suggest a specific improvement. A lighter robot might turn faster but lose traction; a stronger motor might add heat and current draw. Every improvement has a system-level cost.
Prepare for Competitions and Demonstrations
For an event or demo:
- Read the current official rules and inspection checklist.
- Label batteries and connectors.
- Bring compatible tools and safe spare parts.
- Check all fasteners and guards.
- Test the emergency cutoff.
- Confirm that the robot is safe to transport and store.
- Keep a short pre-run checklist.
- Practice the robot’s intended behavior under realistic conditions.
Robot Wrestling™ event formats may vary, so always use the organizer’s latest rules. Our competition page and event announcements can help you keep up with league coverage.
🔒 Robot Safety, Maintenance, and Long-Term Reliability
Safety is part of performance. A robot that is difficult to disarm, charge, inspect, or repair is not a robust design.
Before testing:
- Remove or restrain hazardous moving parts until the test area is ready.
- Secure the robot on a stable surface.
- Keep hands, hair, clothing, and loose items clear of moving parts.
- Use an accessible power cutoff.
- Inspect batteries, connectors, and cables for damage.
- Use eye protection where project risks warrant it.
- Follow tool, charger, and event instructions.
After testing:
- Disconnect power before maintenance.
- Check for loose screws, cracked parts, overheated wiring, and battery damage.
- Clean dust or debris from moving components.
- Record faults and repairs.
- Store batteries according to the manufacturer’s guidance.
For public demos, competitions, or high-energy systems, use a designated test area and follow the event’s safety process. The OSHA machine-guarding overview offers general background on guarding moving machinery, while local regulations and competition rules govern the specific activity.
❓ Frequently Asked Questions About Robot Design and Building
How do robot battling tournaments work?
Robot battling tournaments use event-specific rules to define weight classes, permitted robot designs, arena conditions, match length, scoring, and safety inspections. Some formats reward pushing or control; others may allow particular active mechanisms. The precise format varies, so never assume another league’s rules apply.
At a high level, competitors register a robot, pass technical and safety checks, compete in assigned matches, and advance or score according to the event format. Read the organizer’s current rules and confirm questions with event officials before building. Our Robot Wrestling™ competition coverage and event announcements provide league-related updates.
What should a first-time competitor prioritize?
Start with a dependable drive base, secure battery mounting, robust wiring, and a design you can inspect quickly. A complicated mechanism is only an advantage if it works reliably and is allowed by the rules.
What is the official Robot Wrestling League?
Robot Wrestling™ covers the official Robot Wrestling League and its robot battles and designs. Because competition formats and event requirements can change, use the league’s current published rules and event announcements as the authority for a particular tournament.
Do not infer a weight class, weapon allowance, or match procedure from an older event recap. Check the latest information in Robot Wrestling™ event announcements and contact the organizer if a rule is unclear.
How do you design a robot for a wrestling competition?
Begin with the current rulebook, arena, match format, and weight limit. Then define your strategy: mobility, control, pushing, resilience, or a permitted active mechanism. Design the chassis and power system around that strategy, and leave room for repair access.
A sensible sequence is:
- Confirm legal dimensions, weight, and mechanisms.
- Choose the core strategy.
- Estimate mass and power budgets.
- Build a simple, reliable drive system.
- Prototype high-risk mechanisms separately.
- Protect batteries, wiring, and controls.
- Test traction, turning, recovery, and fault behavior.
- Complete the event’s safety checks.
The NHRL rules show why event-specific rules matter, but competitors must follow the rules of their own league.
What materials are best for building a durable battle robot?
There is no universal best material. Aluminum, steel, polycarbonate, and other engineering materials serve different roles, and the right choice depends on the robot’s design, weight limit, impact loads, fabrication method, and event rules.
Use manufacturer material data and test real parts when possible. A material’s thickness, shape, support, fasteners, and manufacturing quality all affect durability. For a beginner, prioritize a mechanically sound design and protected components over chasing a single “toughest” material.
Is a 3D-printed battle-robot part durable enough?
It may be suitable for brackets, guides, covers, and other roles depending on the filament, print orientation, geometry, and load. Do not assume a printed part is appropriate for a high-impact or safety-critical function without testing and checking league rules.
How do you choose motors for a robot wrestling design?
Choose motors based on the robot’s mass, desired speed, wheel size, terrain, gearing, duty cycle, and available battery power. Check continuous torque and current, stall current, voltage, thermal limits, and motor-driver compatibility.
A motor with a high advertised speed may provide poor pushing performance if its gearing and wheel size do not suit the robot. Test the drive under representative load and inspect for heat. For weapon systems, follow the specific league’s rules and have the design reviewed by a qualified person.
What are the rules for building a robot for a wrestling league?
Rules depend on the league and event. They may cover weight, dimensions, materials, active mechanisms, radio control, batteries, weapon restraint, power cutoff, inspection, and safe transport. Some events restrict features that others permit.
The rulebook for your event is the source to trust. Check its current version before designing, ask officials about ambiguous requirements, and bring the robot in the configuration required for inspection. Do not rely on forum posts or another competition’s rules as a substitute.
How can you make a combat robot more stable and harder to flip?
Start by keeping heavy components low and securely mounted, using a chassis layout that maintains useful wheel contact, and protecting vulnerable parts. Consider how turning, impacts, and mechanisms change the robot’s balance.
No design can guarantee a robot will never flip. Test controlled recovery behaviors and avoid relying on a single feature. The correct approach depends on the arena, rules, robot geometry, and strategy.
What safety features should a robot have before a battle?
Safety features are defined by the event rules, but commonly include a reliable power cutoff, safe weapon restraint during transport and inspection, secure battery retention, protected wiring, and a clear disarming process. Moving mechanisms should remain inactive during handling and inspection unless authorized by the event.
A robot must pass the organizer’s inspection before competing. If you are unsure whether a feature is safe, stop and ask the event officials rather than testing it in an uncontrolled area.
How do you test and improve a robot design before competition?
Test progressively: verify mechanical assembly, inspect wiring, test sensors and motors independently, then run the full robot under realistic conditions. Record performance and failures after each trial.
Prioritize repeatability, not one lucky run. Measure turning, traction, runtime, temperatures, and recovery. Change one design variable at a time, then repeat the same test so you can tell whether the change helped.
Is it better to build from a kit or design from scratch?
A kit is usually the better starting point if you want to learn basic construction and programming with fewer sourcing problems. Designing from scratch gives you more control but adds responsibility for compatibility, fabrication, wiring, and debugging.
A strong path is to build a kit, modify one subsystem, and then design a custom robot once you understand the parts and constraints.
What should beginners learn first: mechanics, electronics, or coding?
Learn enough of all three to build a working system, but start with the simplest project that combines them. A basic rover teaches structure, motors, power, and code together. If one part is unfamiliar, use a kit or tutorial for that subsystem, then experiment with a controlled modification.
The goal is not to master every discipline before starting. It is to build a small robot, understand what it does, and improve it deliberately.